VA-Mechatronics
Accessible Robotics & Motion Control
Engineered for transparency, modern distributed CAN control, and high-precision absolute joint feedback.
KARL-Robot
A custom 6-axis robot arm engineered with magnet encoders for true absolute feedback, backdrivability, and real-time trajectory streaming.
Explore KARL-Robot →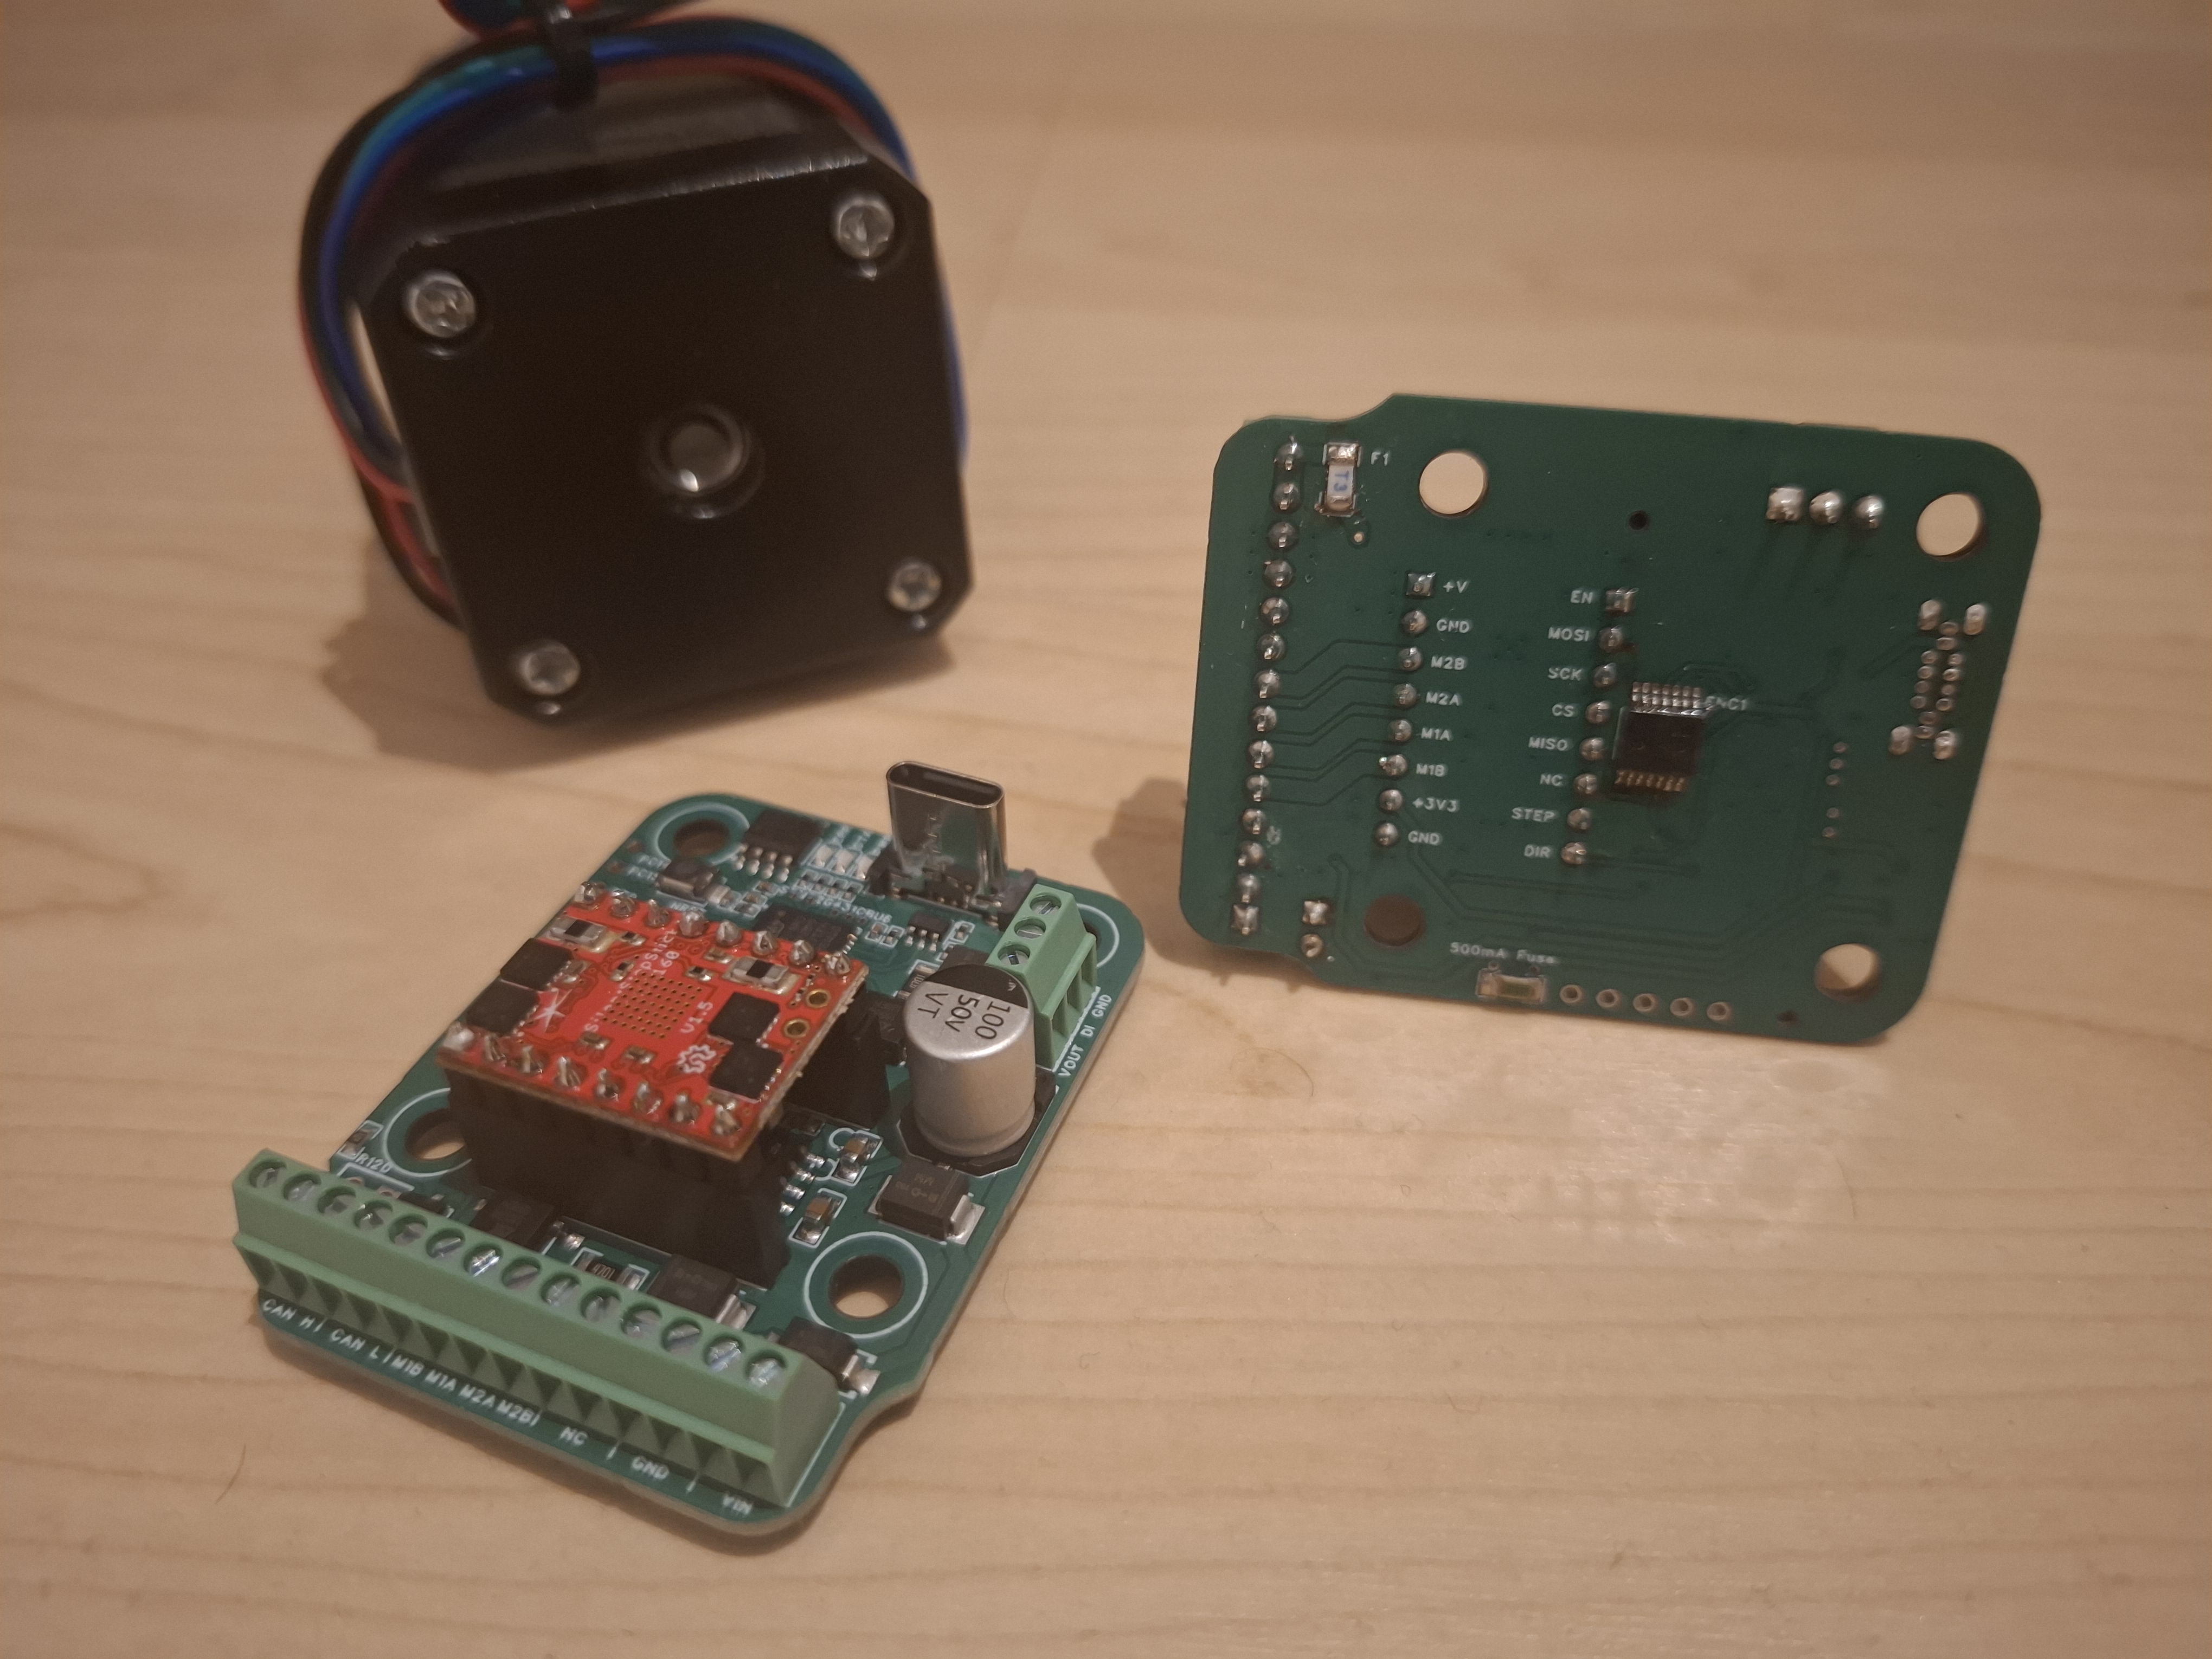
CAN-MCU
A compact, STM32G431-based motion controller in NEMA 17 format. Features integrated magnetic aboslute encoding and 24V, hardware E-Stop, CAN daisy-chaining.
Explore CAN-MCU →Get in Touch or Stay Updated
© 2026 VA-Mechatronics. Built with passion for accessible robotics.