Knick Arm Roboter Lite by VA-Mechatronics
KARL-Robot
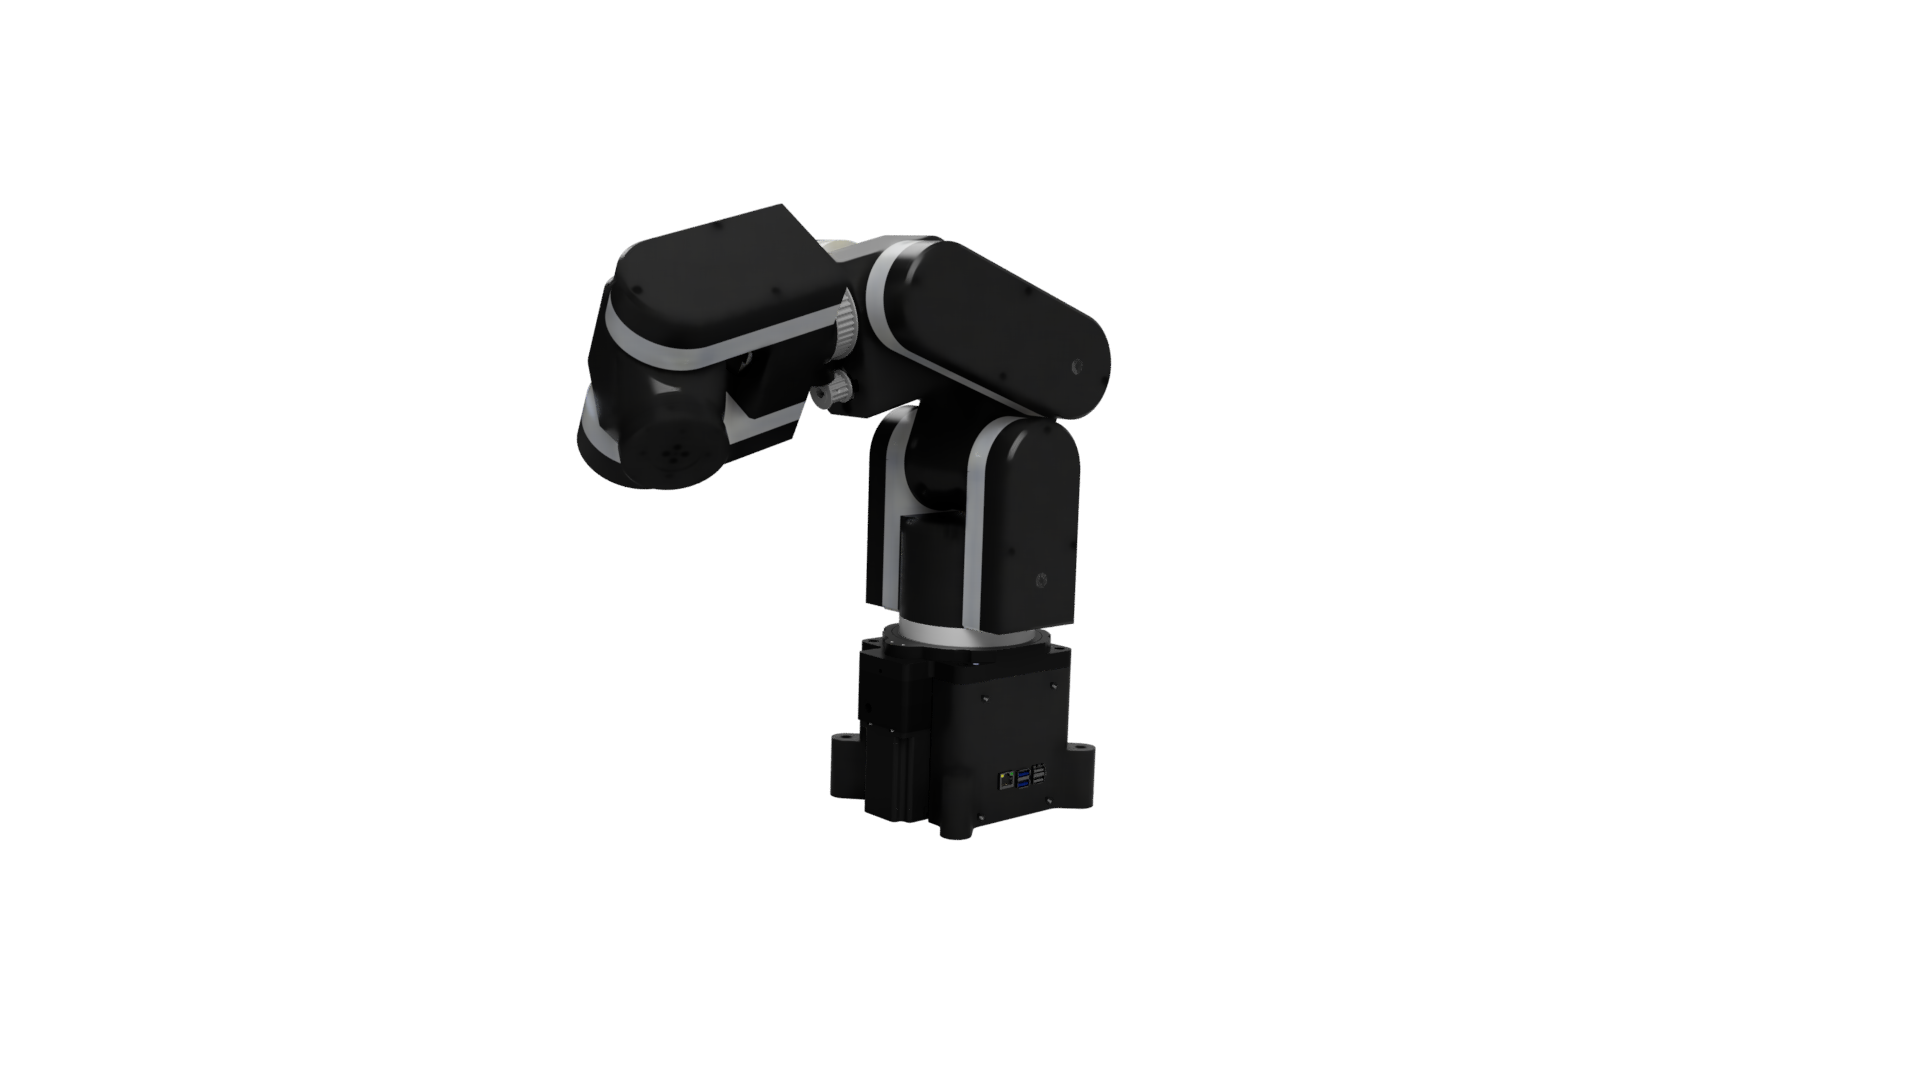
A custom 6-axis robot arm engineered for transparency, modern distributed CAN control, and absolute joint feedback.
Project Links
-
True Absolute Joint Feedback:
Magnet encoders measure arm/output shaft positions directly. Enables backdrivability, hand-guiding, easy point teaching, and real-time PID control. -
Real-Time Trajectory Streaming:
The CAN controller buffers and streams motion trajectories milliseconds into the future, guaranteeing deterministic execution. -
Multi-Client ZMQ Architecture:
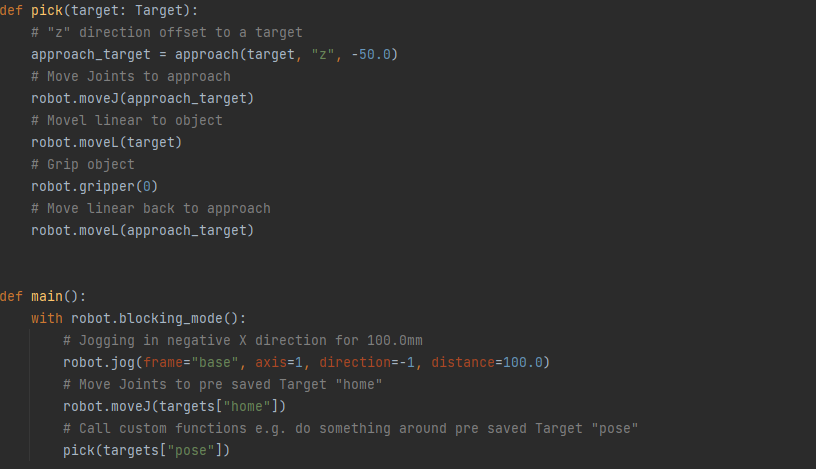
Backend driven via ZeroMQ/TCP-IP. Run automated Python scripts concurrently while the PySide/OpenGL GUI provides live 3D visualization. -
Simulation Mode on Localhost:
Test and write Python scripts without physical hardware connected. -
Distributed Motion Control Units:
Custom STM32 PCBs (NEMA 17 size) mounted directly at the joints. Clean daisy-chain wiring with 24V supply, CAN and NC loop. -
3D Printed & Off-the-Shelf:
Accessible hardware combining 3D printing with standard off-the-shelf components. -
Current Status:
V2 testbed operational! Market ready V3 Facelift releasing soon.
© 2026 VA-Mechatronics. Built with passion for accessible robotics.