Motion Control Unit by VA-Mechatronics
CAN-MCU
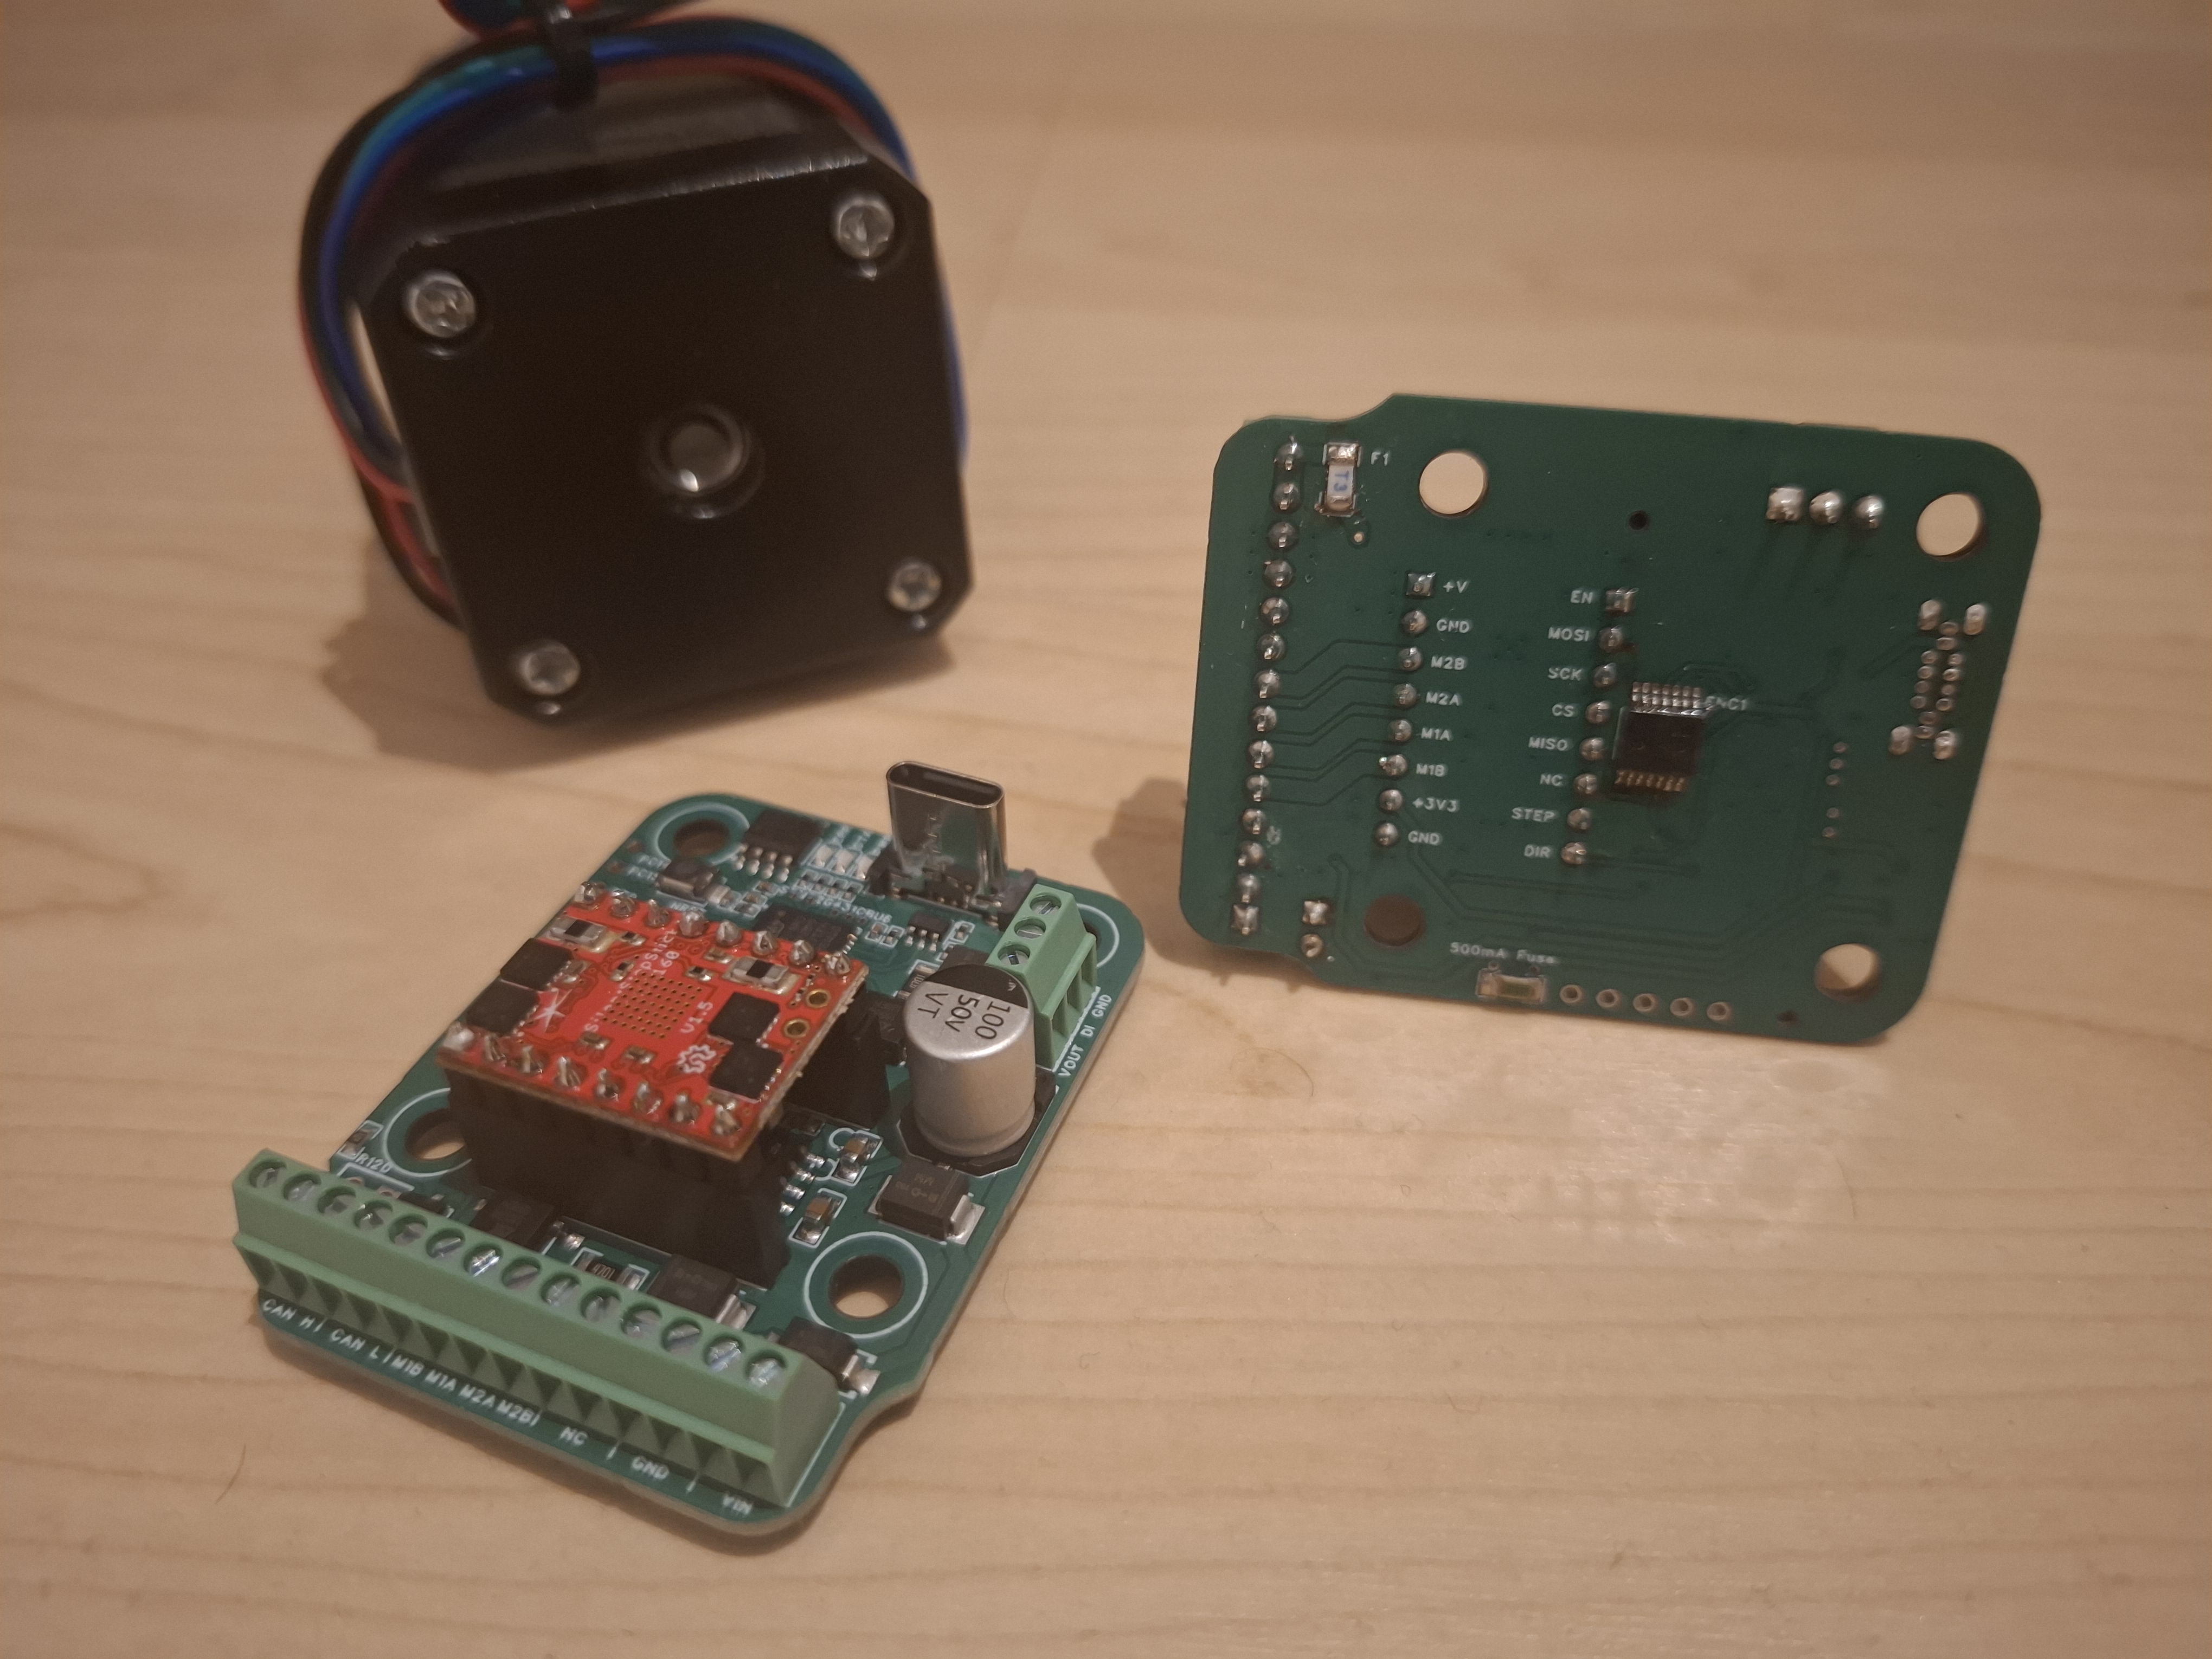
A custom engineered STM32-based PCB for modern distributed CAN control, NEMA 17 mounting, and absolute magnetic position feedback.
Project Links
-
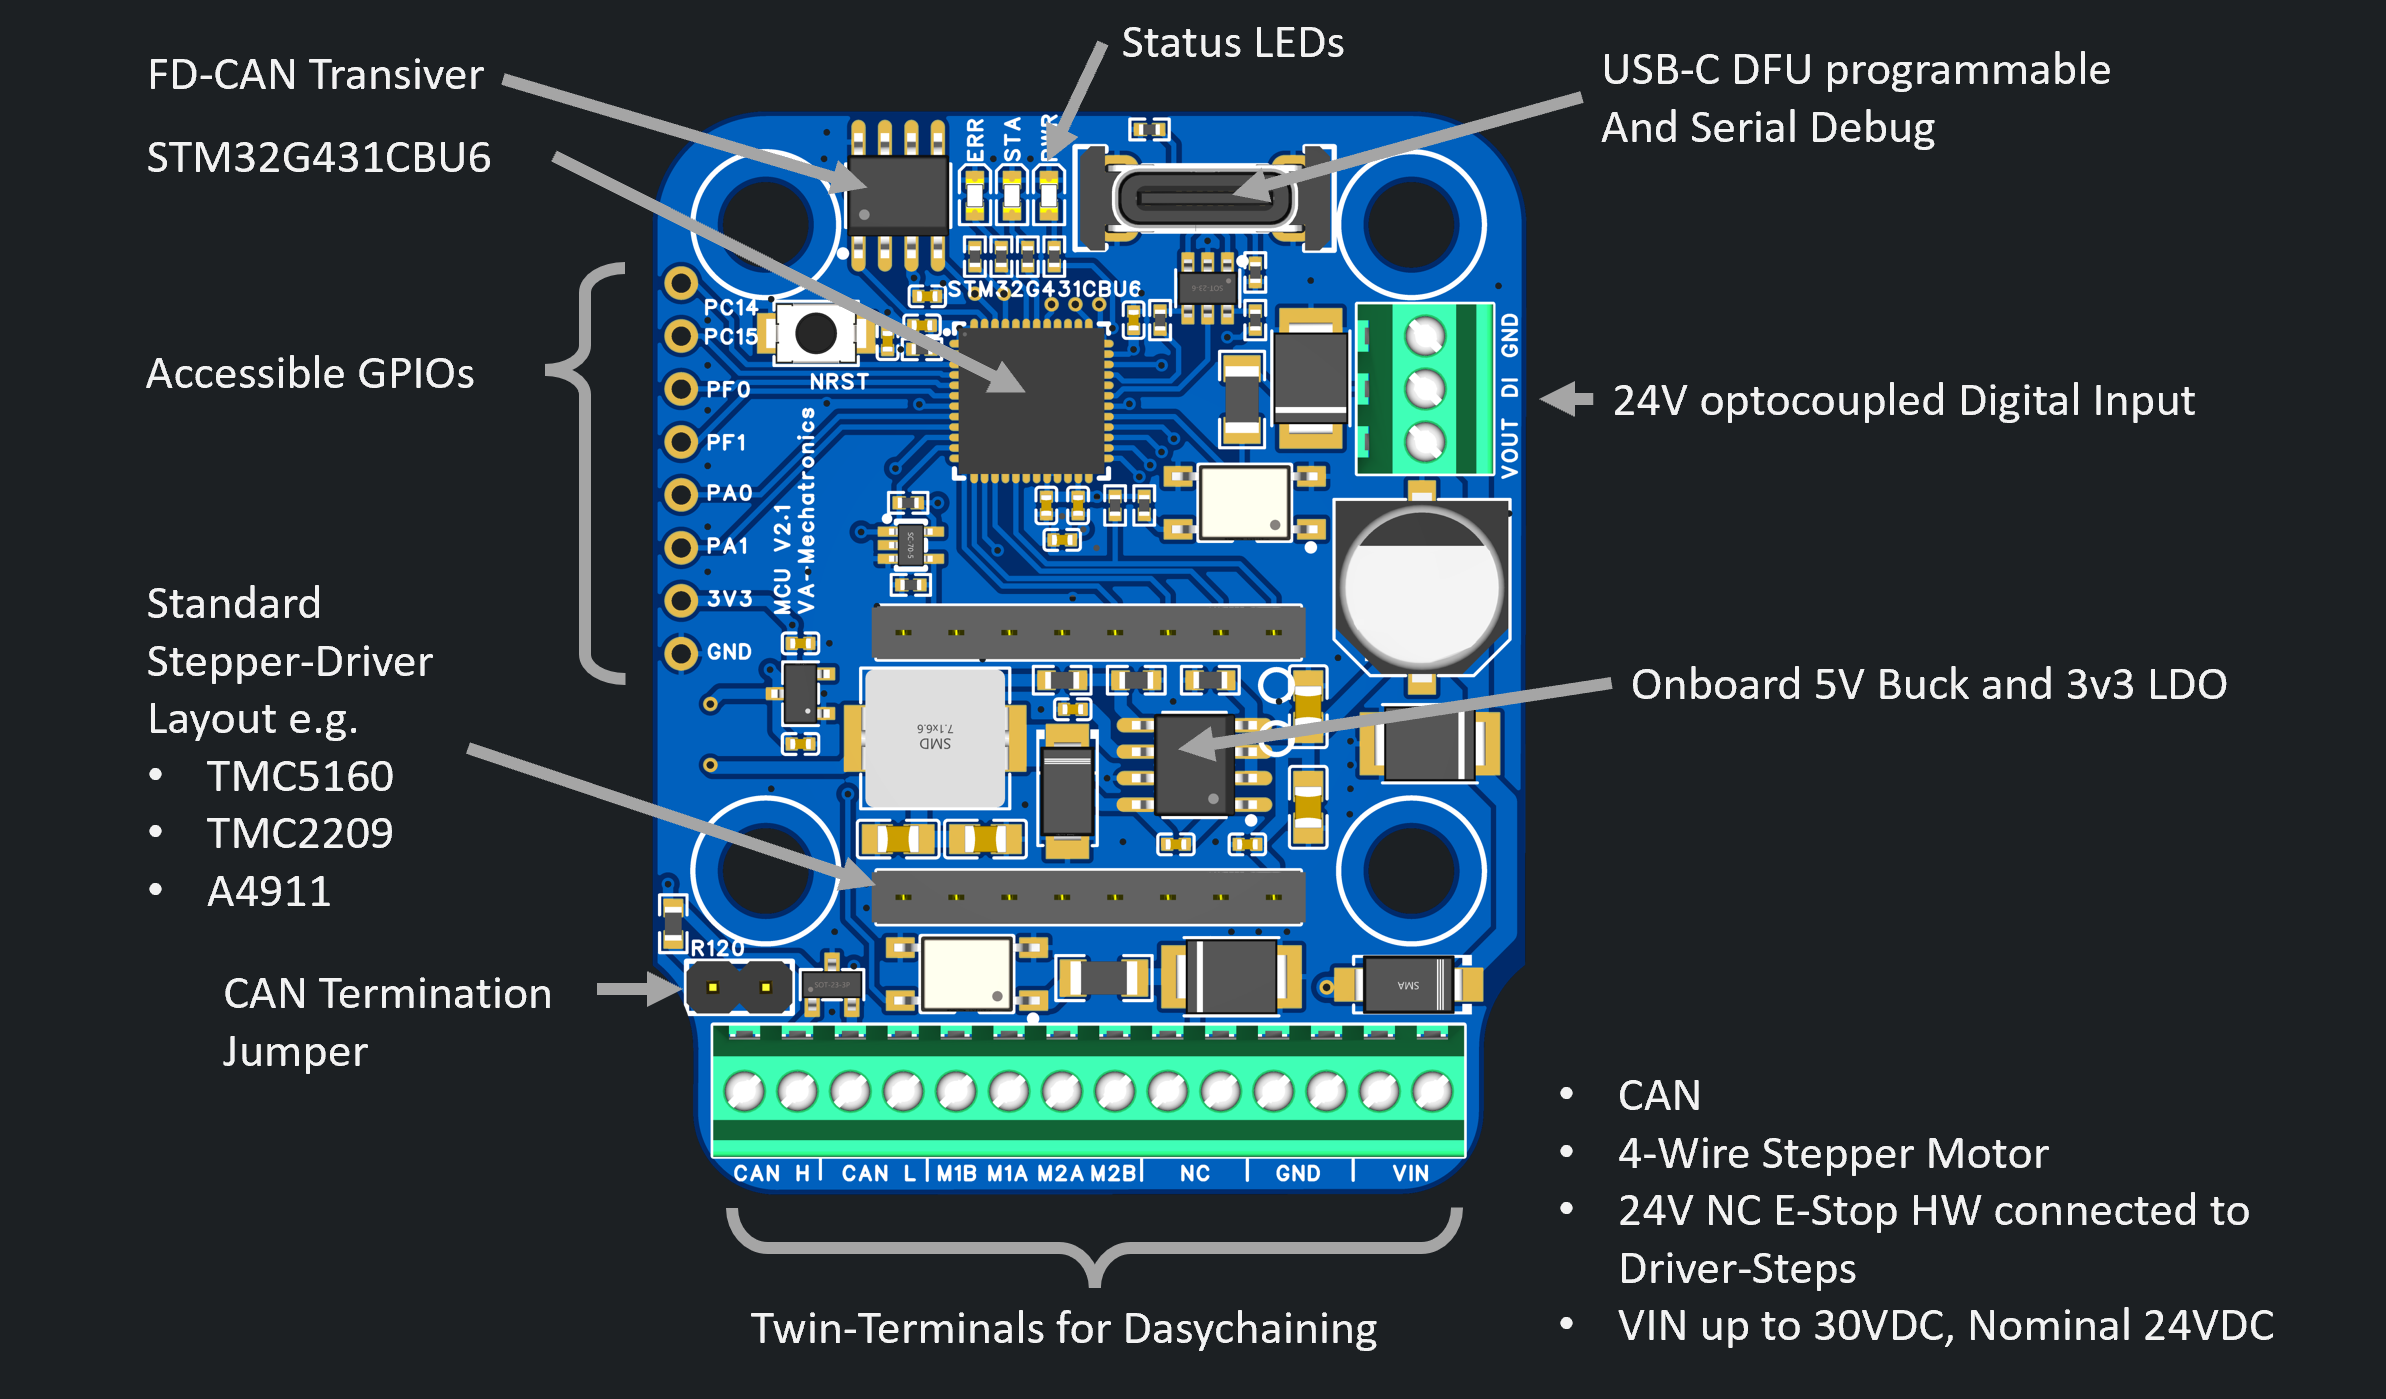
STM32G431CBU6 High-Performance Core:
Powered by an ARM Cortex-M4 MCU. Programmed via PlatformIO in VS Code using STM32 HAL libraries. -
SPI Magnetic Absolute Encoder:
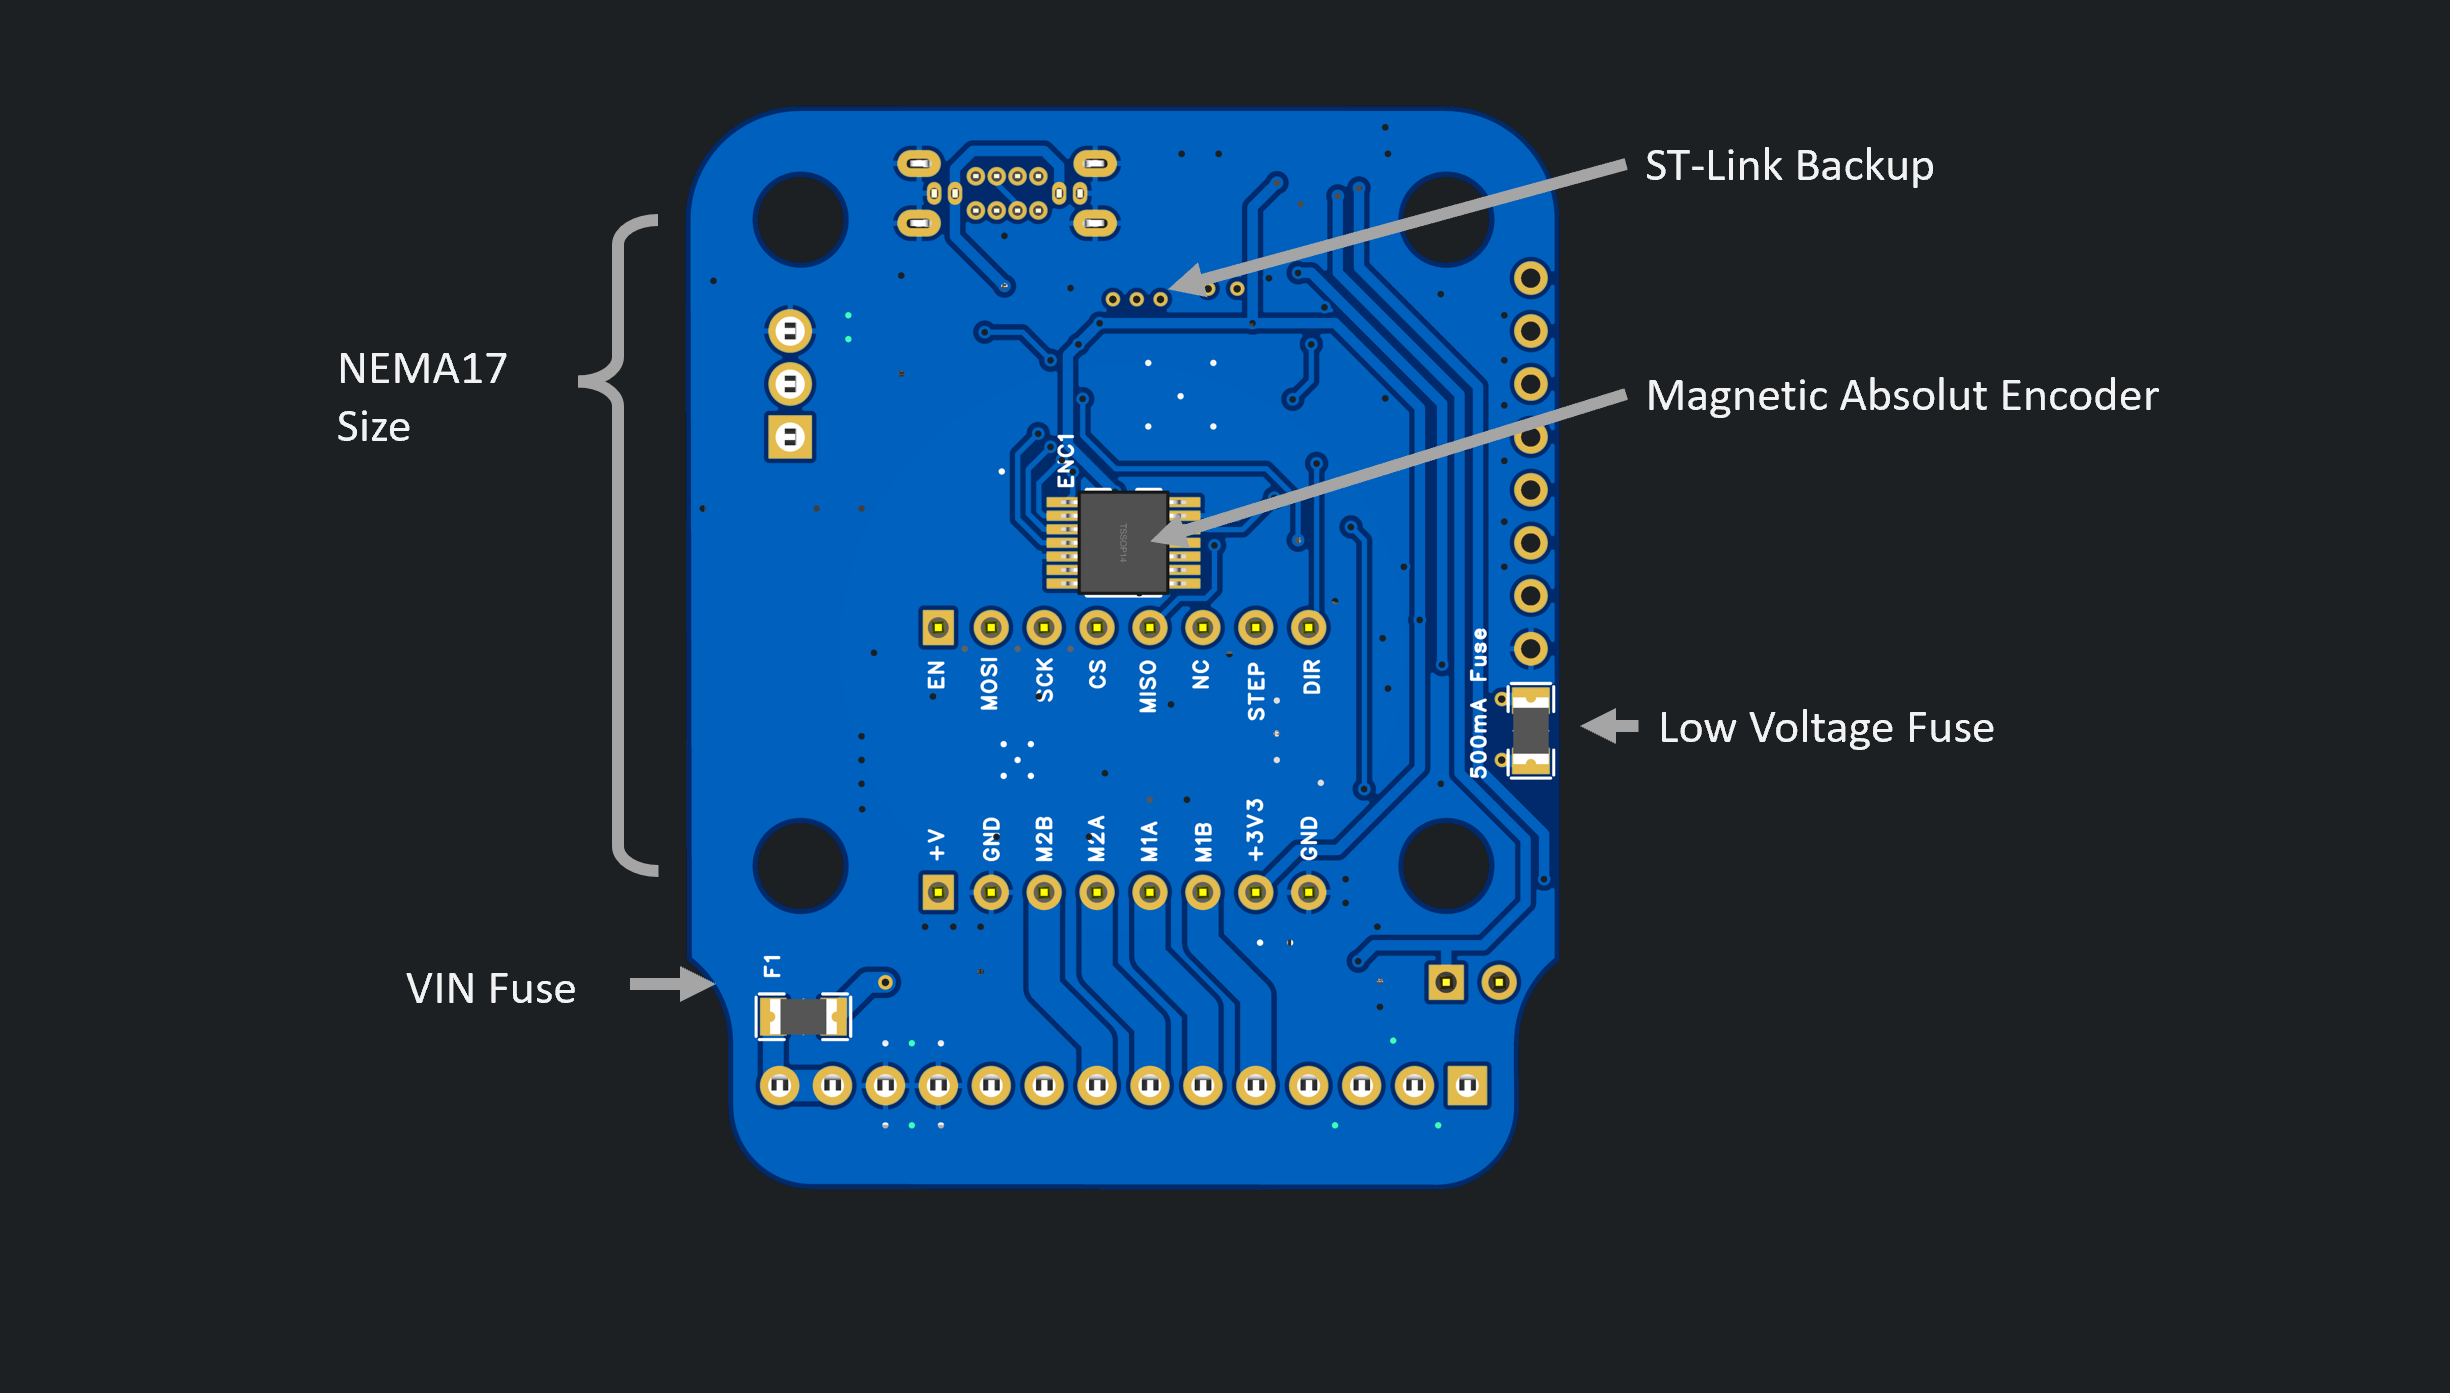
Integrated magnet encoder on PCB backside for true position feedback and real-time PID control. -
Standard Stepper Driver Socket:
Compatible with popular StepStick drivers (TMC5160, TMC2209, A4911) for easy replacement and hardware flexibility. -
Daisy-Chained Terminals & Hardware Safety:
Differential FD-CAN bus with screw terminals. 24V Hardware NC-Loop (E-Stop) gated via AND-logic directly to the driver step line. -
Onboard Power & Industrial I/O:
Integrated 24V DC input support with 5V & 3.3V LDOs, 1x 24V optocoupled digital input, and accessible 3.3V GPIOs. -
NEMA 17 Form Factor & USB-C DFU:
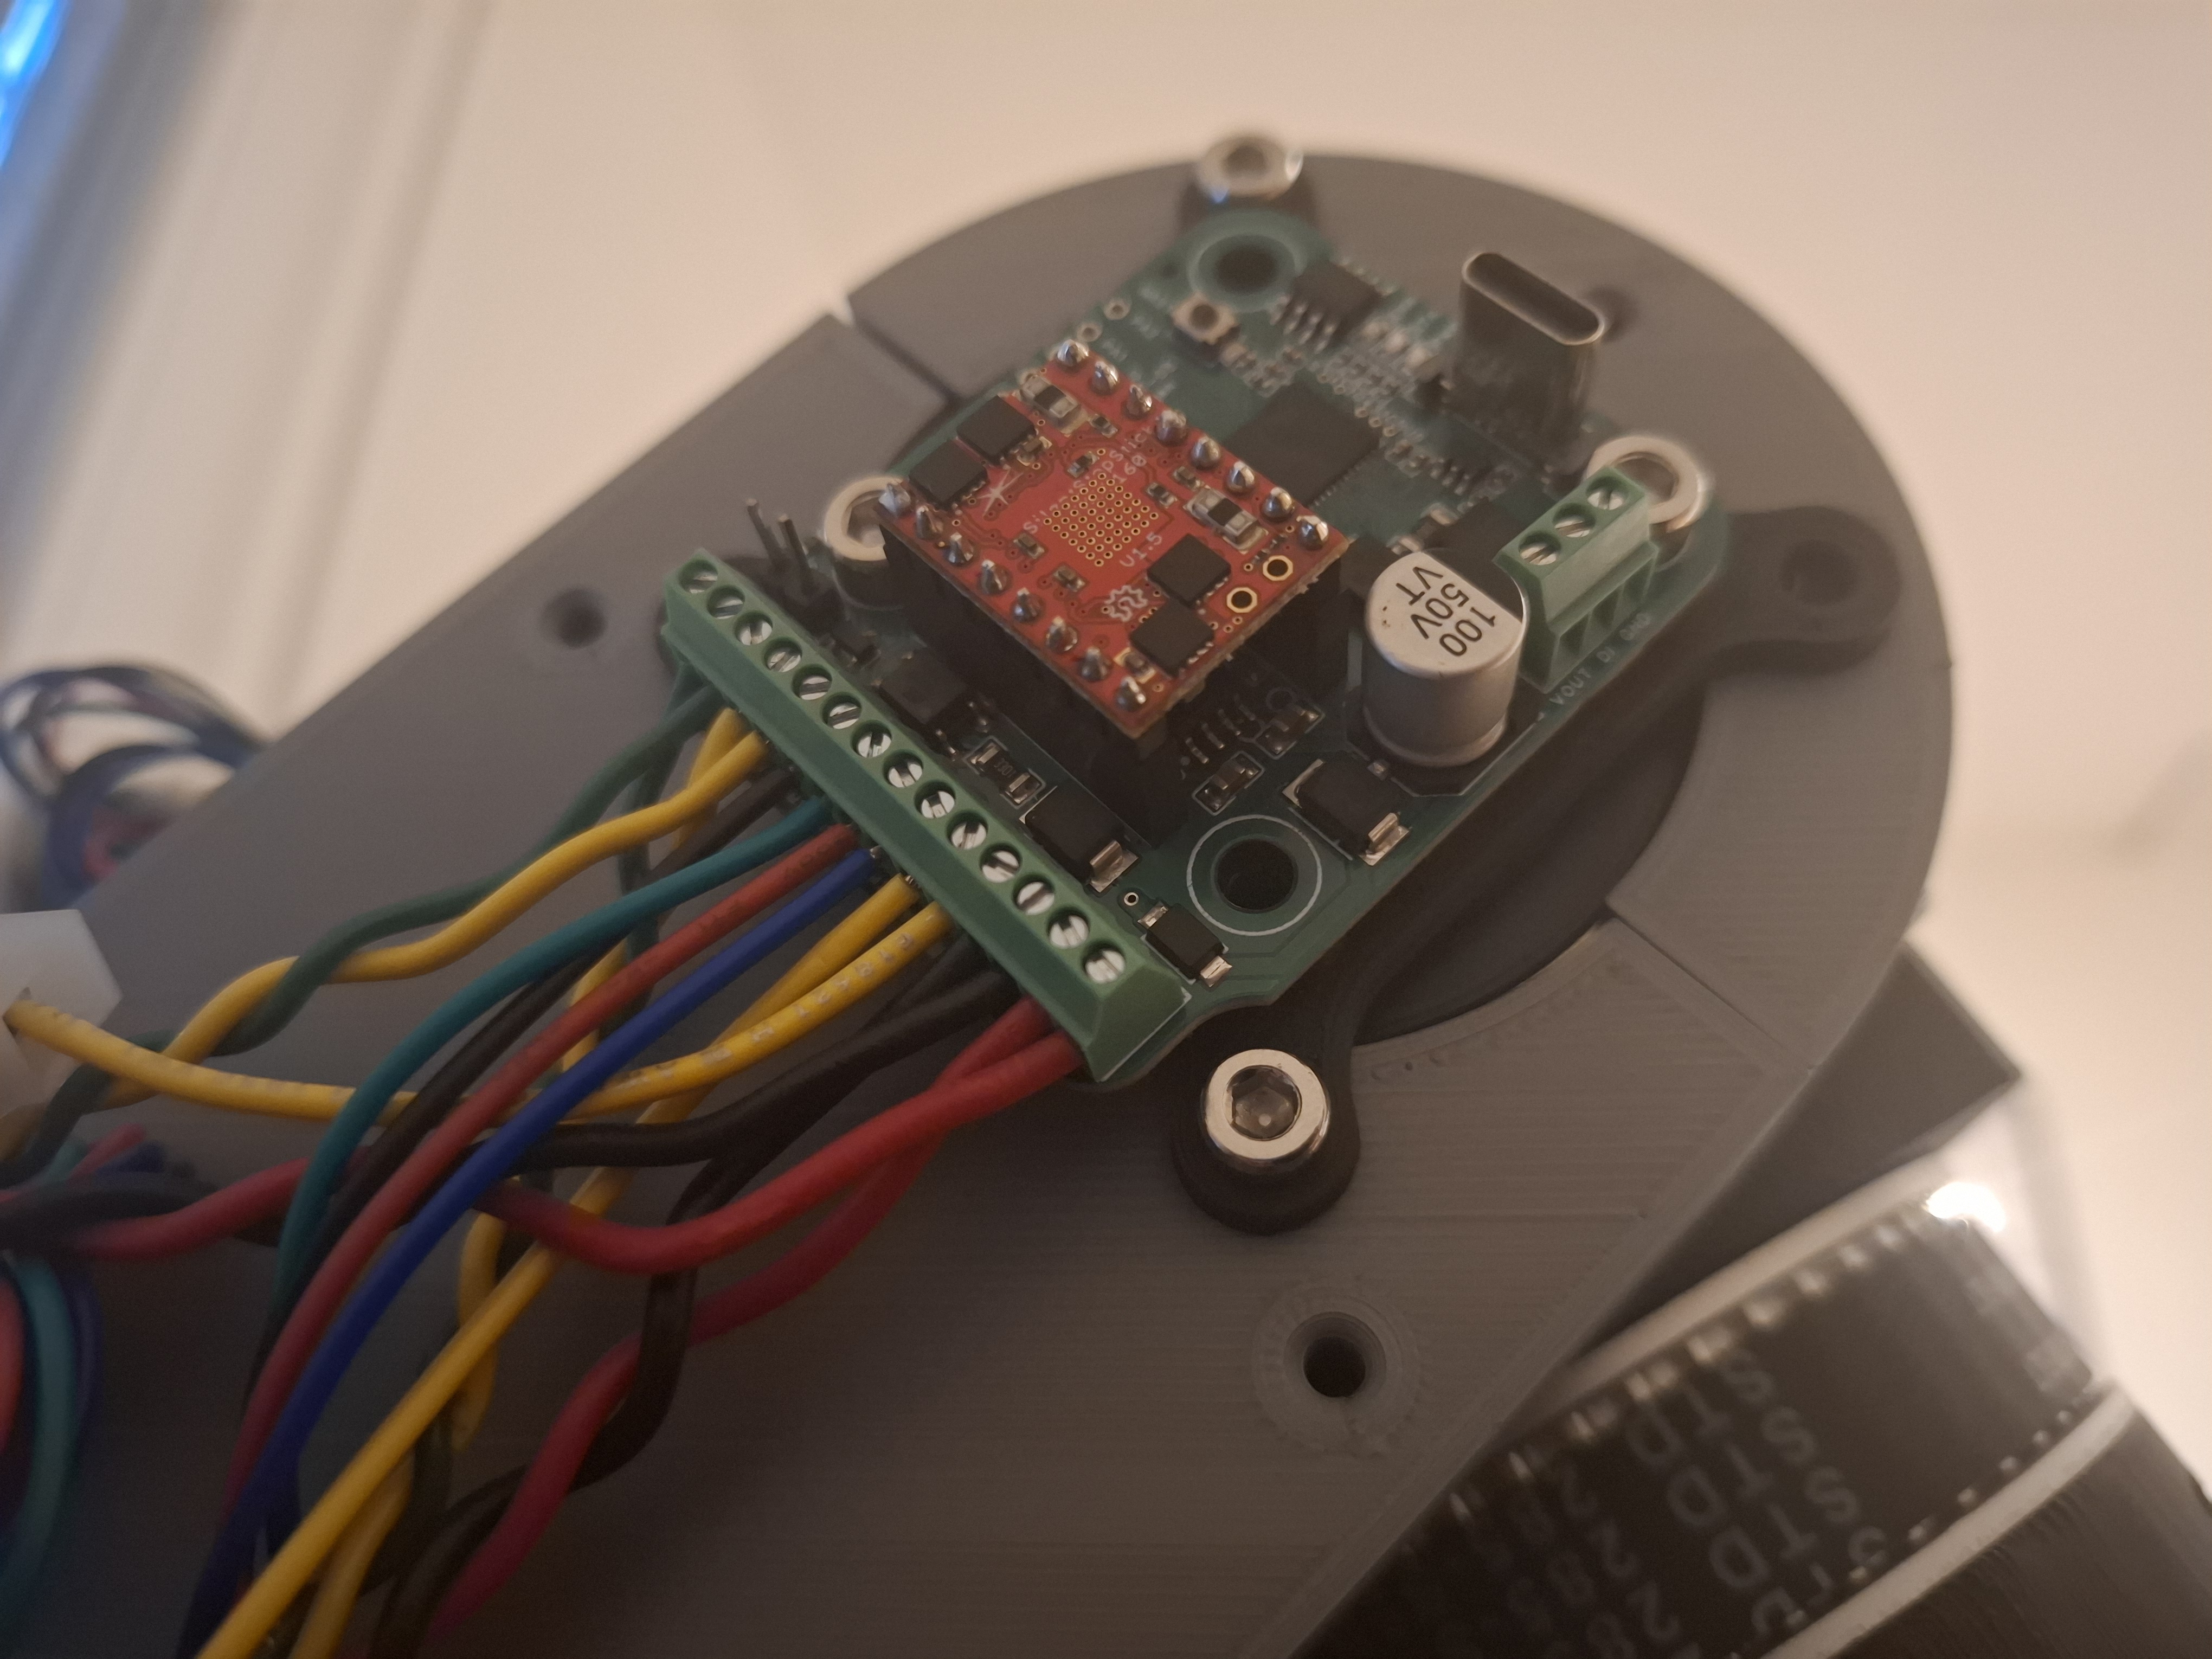
Mounts directly to the back of NEMA 17 motors. Native USB-C DFU bootloader for simple firmware flashing. -
Field-Tested Performance:
Proven in active service powering the 6-axis KARL-Robot.
© 2026 VA-Mechatronics. Built with passion for accessible robotics.